
南京草莓采摘机器人 Strawberry Harvesting Robot
央视节目组牵线,我们去了南京溧水的金色庄园。这里的草莓基地有5200多亩。温室里,一串草莓有红有青,成熟的那颗有时正好被挡住。机械臂得从旁边绕进去,留住青果,只摘熟果。熟果很软,摘得再好,放重了也会碰伤。
The CCTV production team introduced us to Golden Manor in Lishui, Nanjing, where the strawberry base covers over 5,200 mu (about 347 hectares). A ripe berry can hang behind an unripe one. The picker must approach without disturbing the fruit in front, then support the ripe berry all the way into its tray.
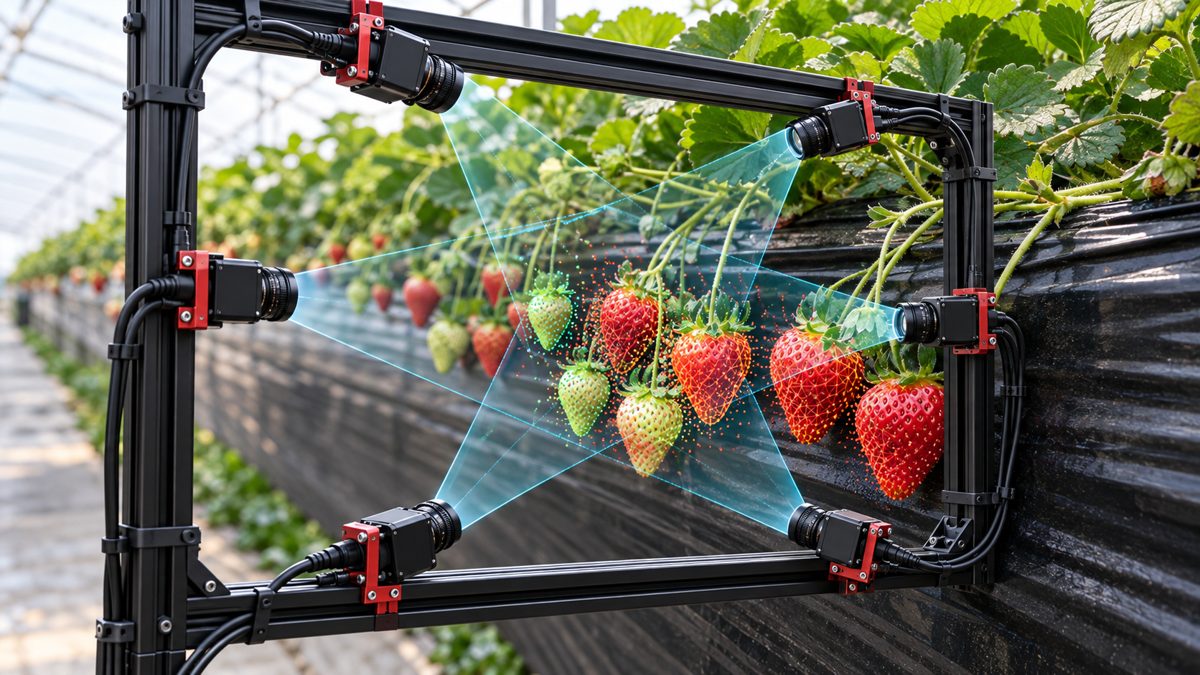
怎样托住一颗熟果 From the row to the tray
我们准备用六台RGB相机从不同角度找熟果,通道两侧各布置一套并联机械臂。采摘时,臂端从侧面绕过青果,从下方托住要摘的那一颗。摘下后轻放进软托,尽量不让草莓悬空掉落。
We are designing the picker around six RGB cameras and two delta arms, one on each side of the aisle. Each arm would reach around unripe fruit, support a ripe berry from below, and lower it into a soft tray to limit bruising.